SO-101 snack pick-and-place with ACT
· PDF report · English
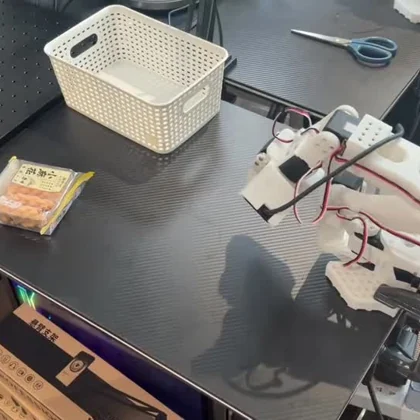
An ACT study connecting 90 dual-camera leader–follower demonstrations, network architecture, training logs and two autonomous physical pick-and-place trials.

Also known as Yanshifu
Experiment Reports
Jeff Liu, also known as Yanshifu, is a co-founder of BAP Lab and Yanshi Robotics. His work focuses on reproducing cutting-edge research, translating it into practical engineering applications, and supporting its wider adoption. He also develops robots that address real-world problems.
Experiments in robotics, machine learning and intelligent systems. Methods, observations and limitations, preserved alongside the original reports.
An ACT study connecting 90 dual-camera leader–follower demonstrations, network architecture, training logs and two autonomous physical pick-and-place trials.
An asymmetric actor–critic with deployment-format observations is trained in Isaac Lab and transferred to MuJoCo, documenting cross-engine control debugging.
An analysis of G1 policies with favorable training metrics but inadequate commanded motion, using measured displacement to examine capability claims.
Expanding the forward-command range on the stock G1 to examine velocity tracking, aerial phases and stability.
Velocity tracking and entropy-coefficient ablations on the stock Isaac Lab G1, with multi-seed training and independent simulation evaluation.
Learning locomotion on the eight-joint Ant, comparing energy penalties and entropy regularization with multi-seed experiments.
PPO training for the Isaac Lab cartpole task, connecting observations, actions, rewards, networks and training curves.
A three-stage study combining universal adversarial-image optimization with AnyAttack fusion, evaluating 6,615 clean/adversarial response pairs and separating output disruption from target-content injection.
A six-variable regression CNN trained on single-frame weather fields, documenting architecture, learning curves, validation errors and overfitting.
Mini-ImageNet experiments compare MAML with a fine-tuning baseline and examine class count, shots and inner-loop update steps.
A C-based HTTPS proxy and a multi-model review module inspect and cross-check potentially misleading information during web browsing.
An IWSLT2017 French-to-English study comparing normalization placement and type, dropout, warmup and weight decay.
Separate VGG-19 and ResNet-34 experiments examine how weight initialization and learning-rate scheduling affect training.
A comparison of adaptive-gradient and momentum methods across networks on MNIST and CIFAR-10, examining loss and accuracy trajectories.
A reinforcement-learning study progressing from Q-learning in a simplified brick game to DQN in Atari Breakout, with implementation, debugging and training observations.
A language-model agent coordinates constrained analysis tools, sepsis data processing and result explanations, with a discussion of layered agent design.
A calibration-card pipeline maps photographed colors to reference colors, documenting data preparation, feature construction, model comparisons and deployment.
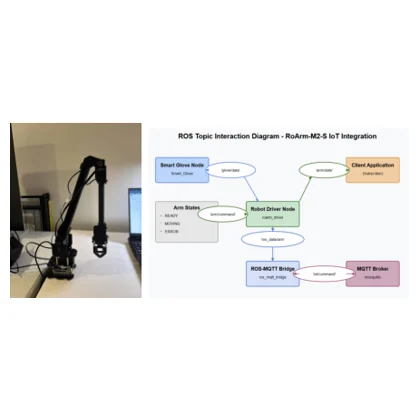
A modular IoT platform connects sensors, actuators, robot arms and smart gloves through a Raspberry Pi hub and MQTT communication.
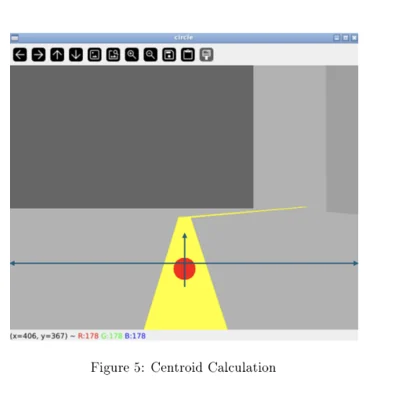
OpenCV locates a colored line centroid for proportional control, with search and obstacle-avoidance states for interrupted tracking.
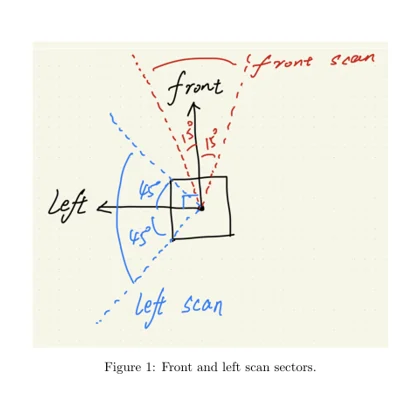
A sensor-based maze navigation study using laser scans, left-wall following and a state machine, with obstacle handling and simulation tests.
Try a different keyword or clear the selected year and topic.